Electric Vehicle Team
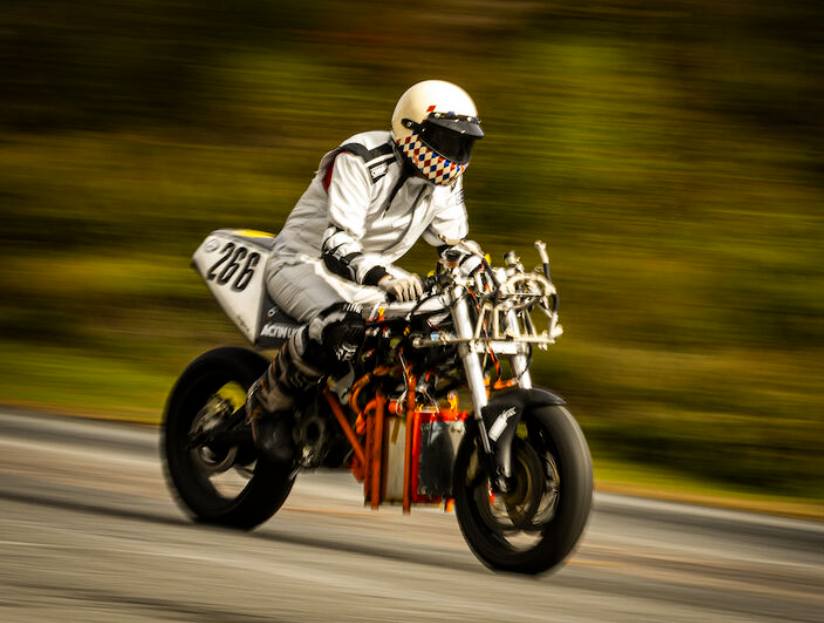
As Mechanical Lead, I was part of re-founding the team. I led the effort to rebuild a Ducati 900SS frame to house a hydrogen fuel cell, motor, and battery, as well as be the structural base for the swing arm. We presented at CES 2024, as part of the Doosan booth.
Skills: CAD, Waterjet, Milling, Welding, Dynamometer testing
Yo-yo manufacturing
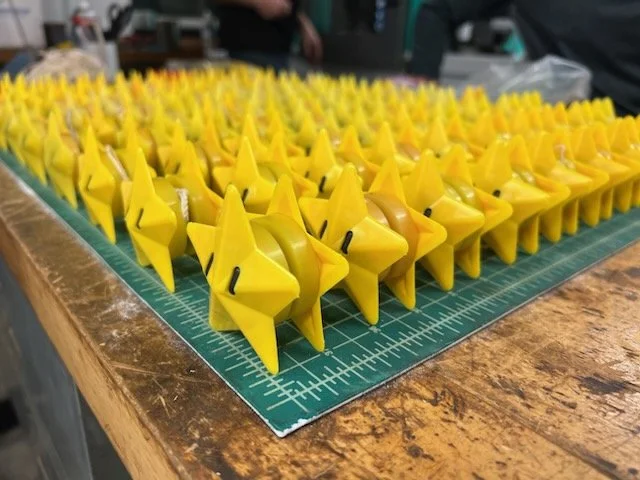
4-person team based class producing 100 yo-yos. I was fully responsible for CAD design / Thermoforming, and maintained shifts operating the injection molder. Learned the importance of considering manufacturing efficiency in design.
Skills: CAD, Injection Molding, Thermoforming, CNC operation
Biomimetic Robotics Lab
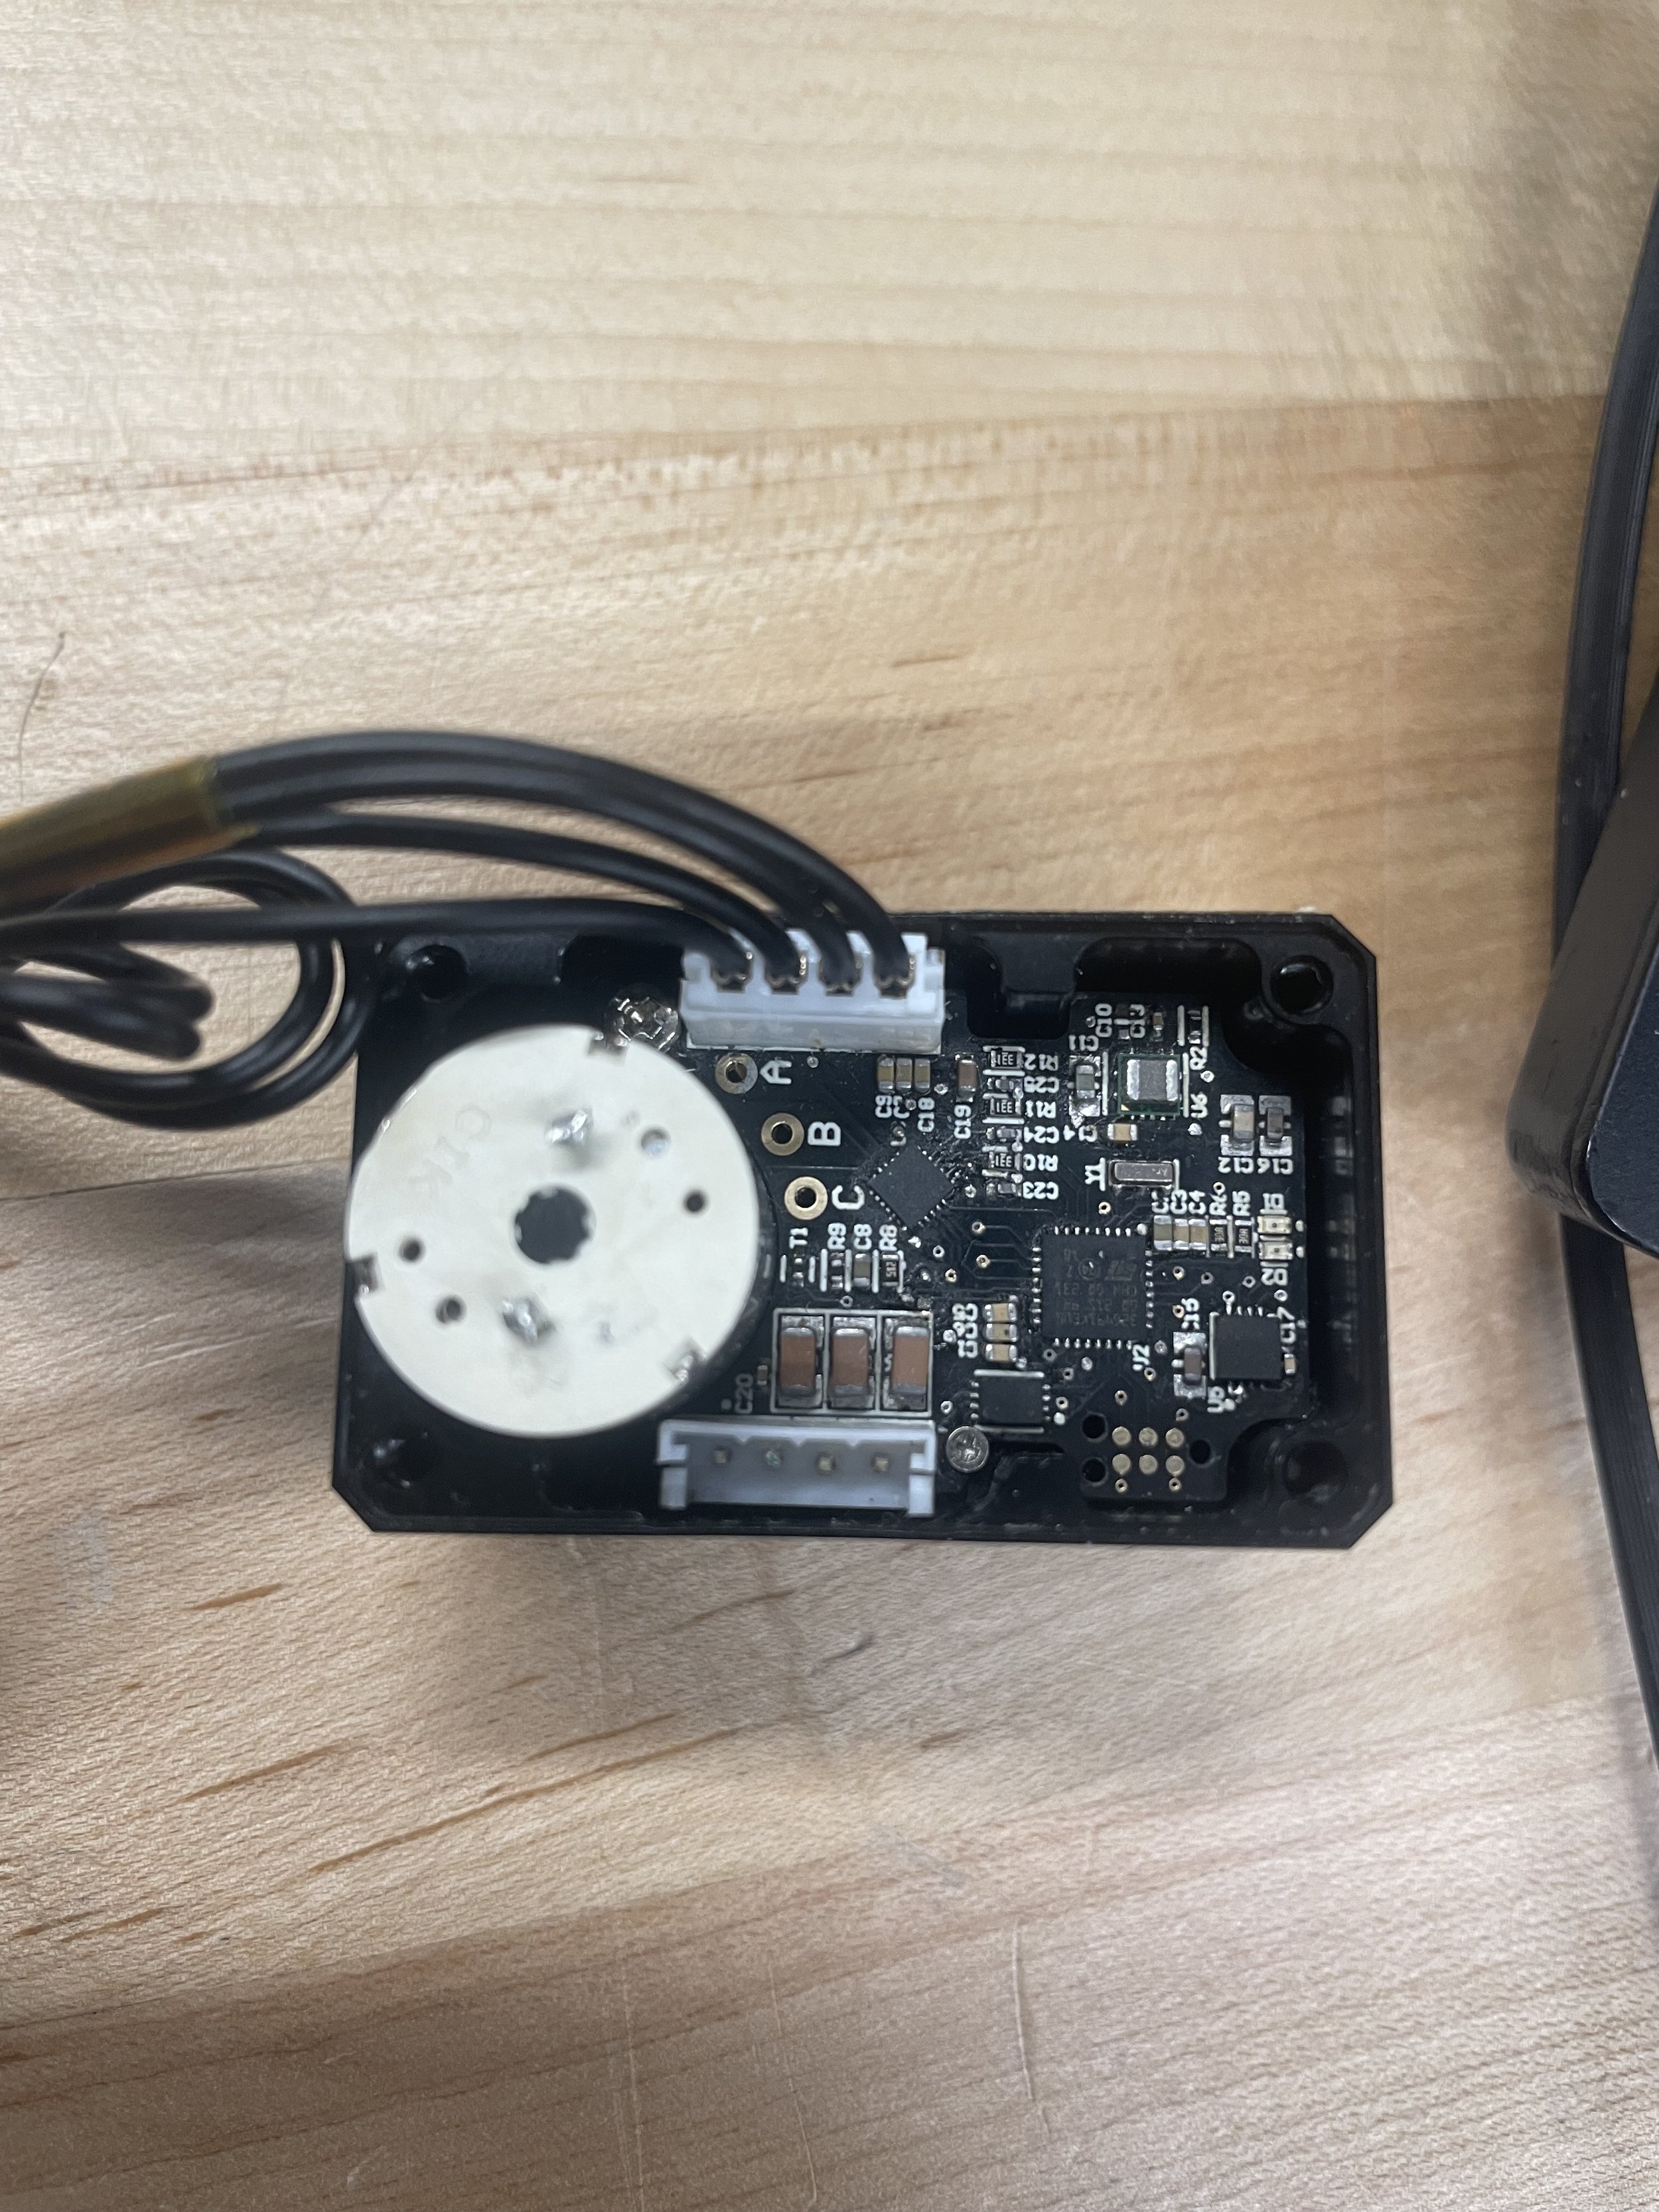
Integrated a servo PCB to use as a quasi-direct-drive motor in a robotic hand. Hand soldered prototype and programmed the STM32 to output I2C and SPI, interfacing with an AS5600 encoder chip.
Skills: Low-level programming, PCB buildup
Bouyancy Pump
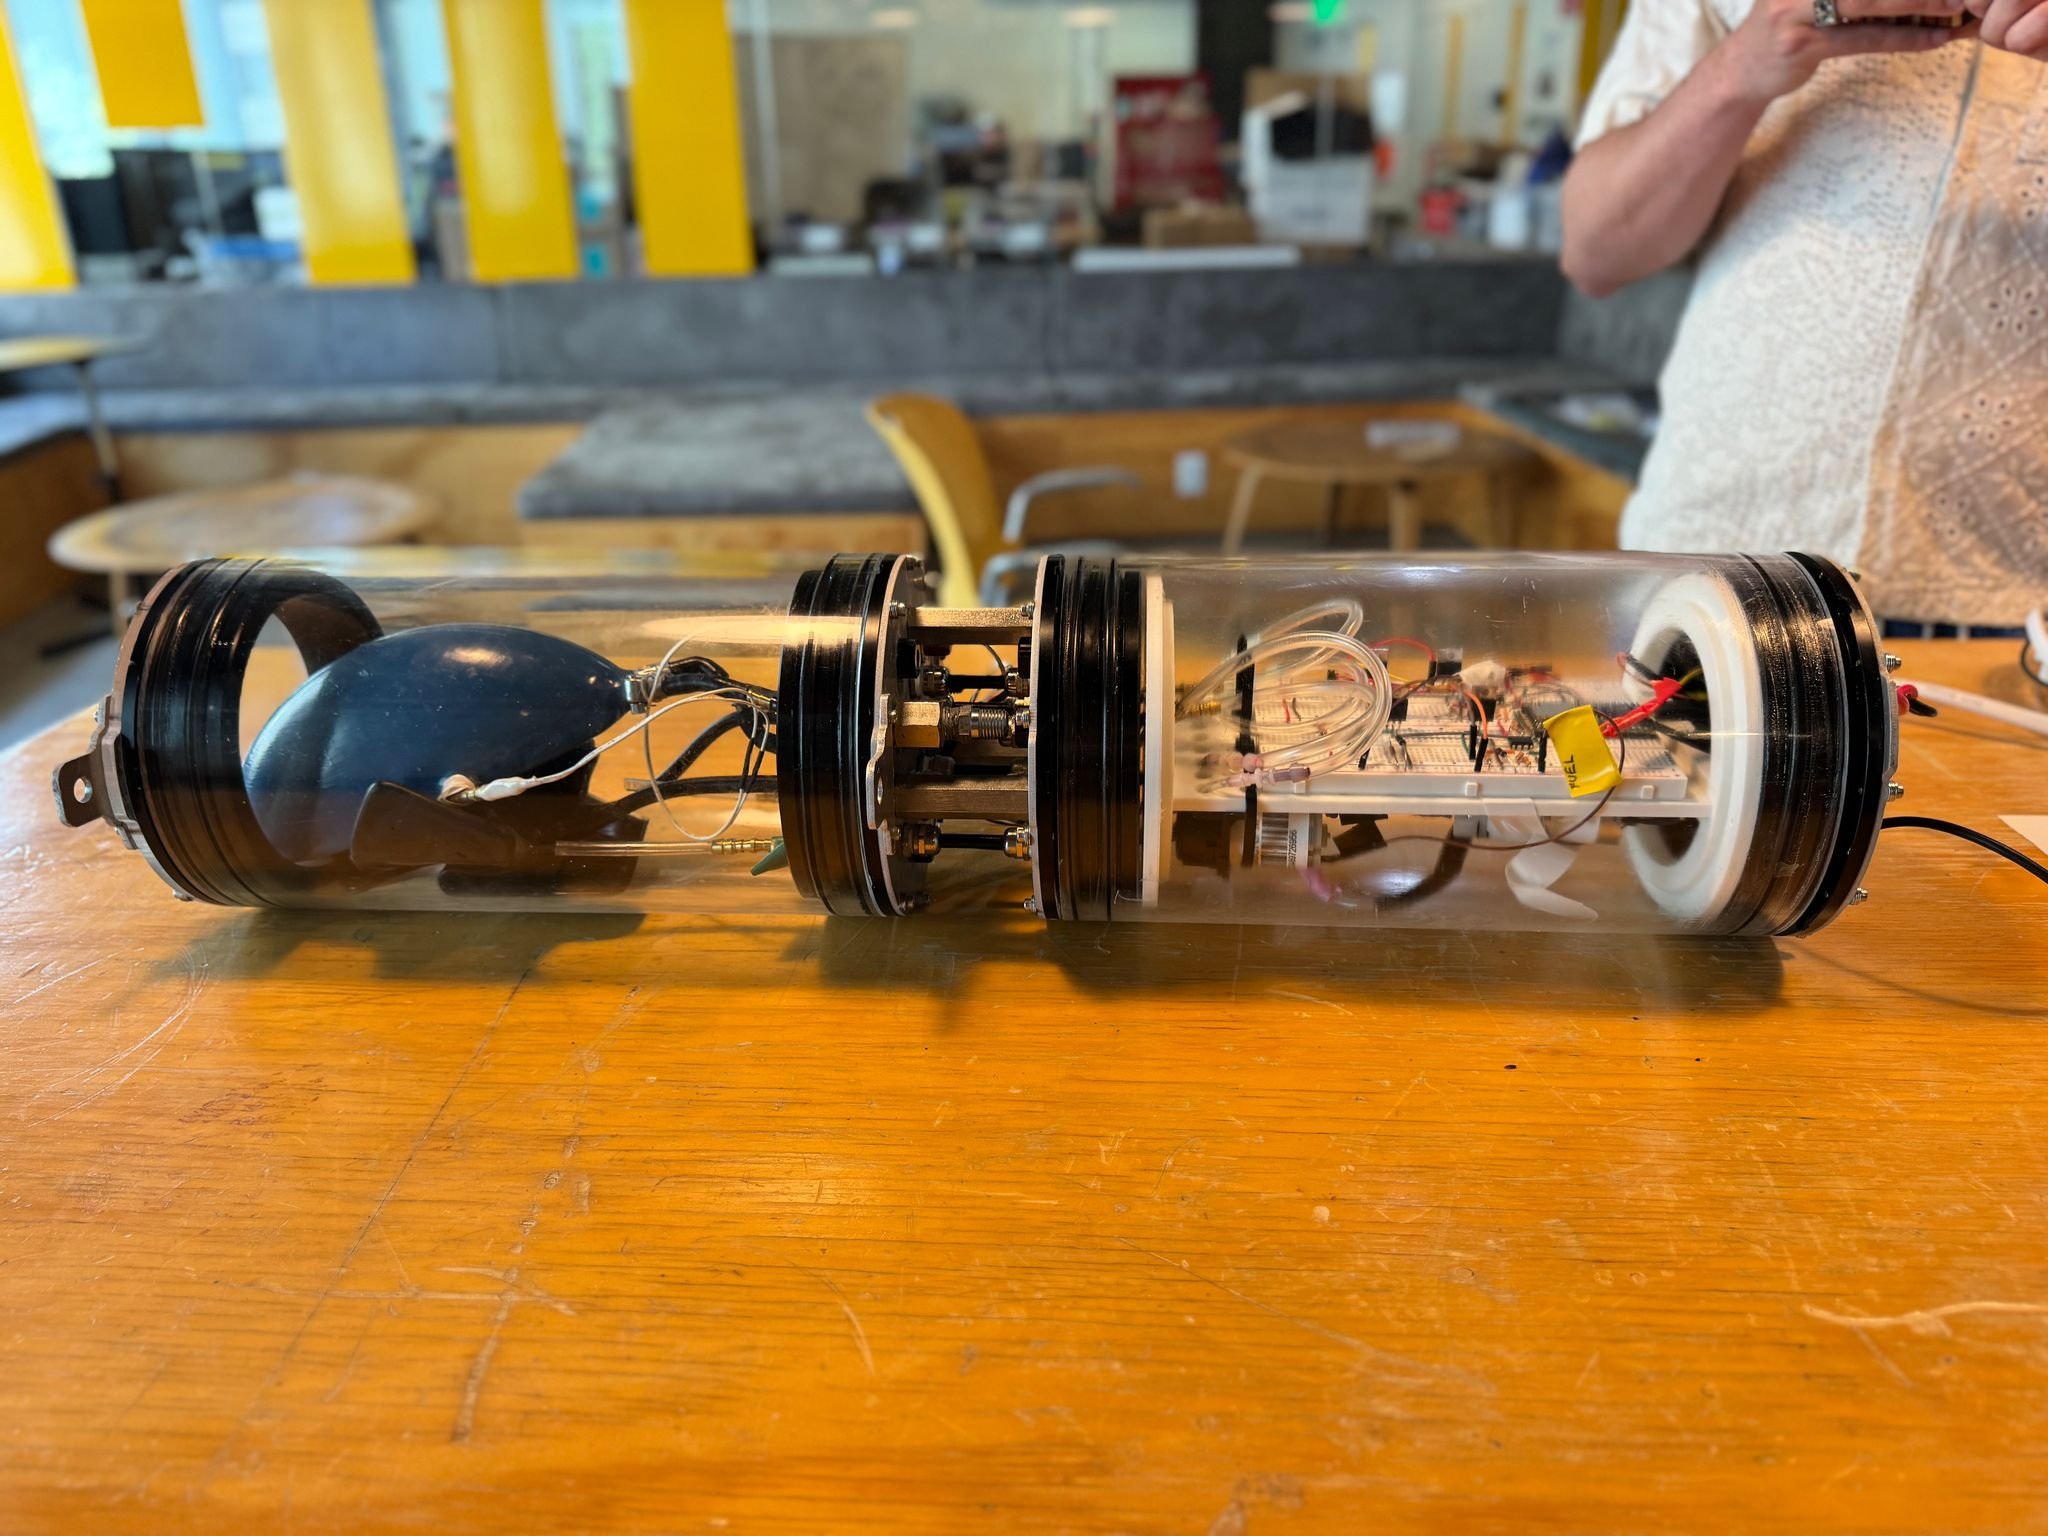
Led electronics design in capstone engineering class, including a PCB. Used various sensors (Thermistor, Pressure) to measure buoyancy performance.
Skills: Altium Designer
Beetle Robot
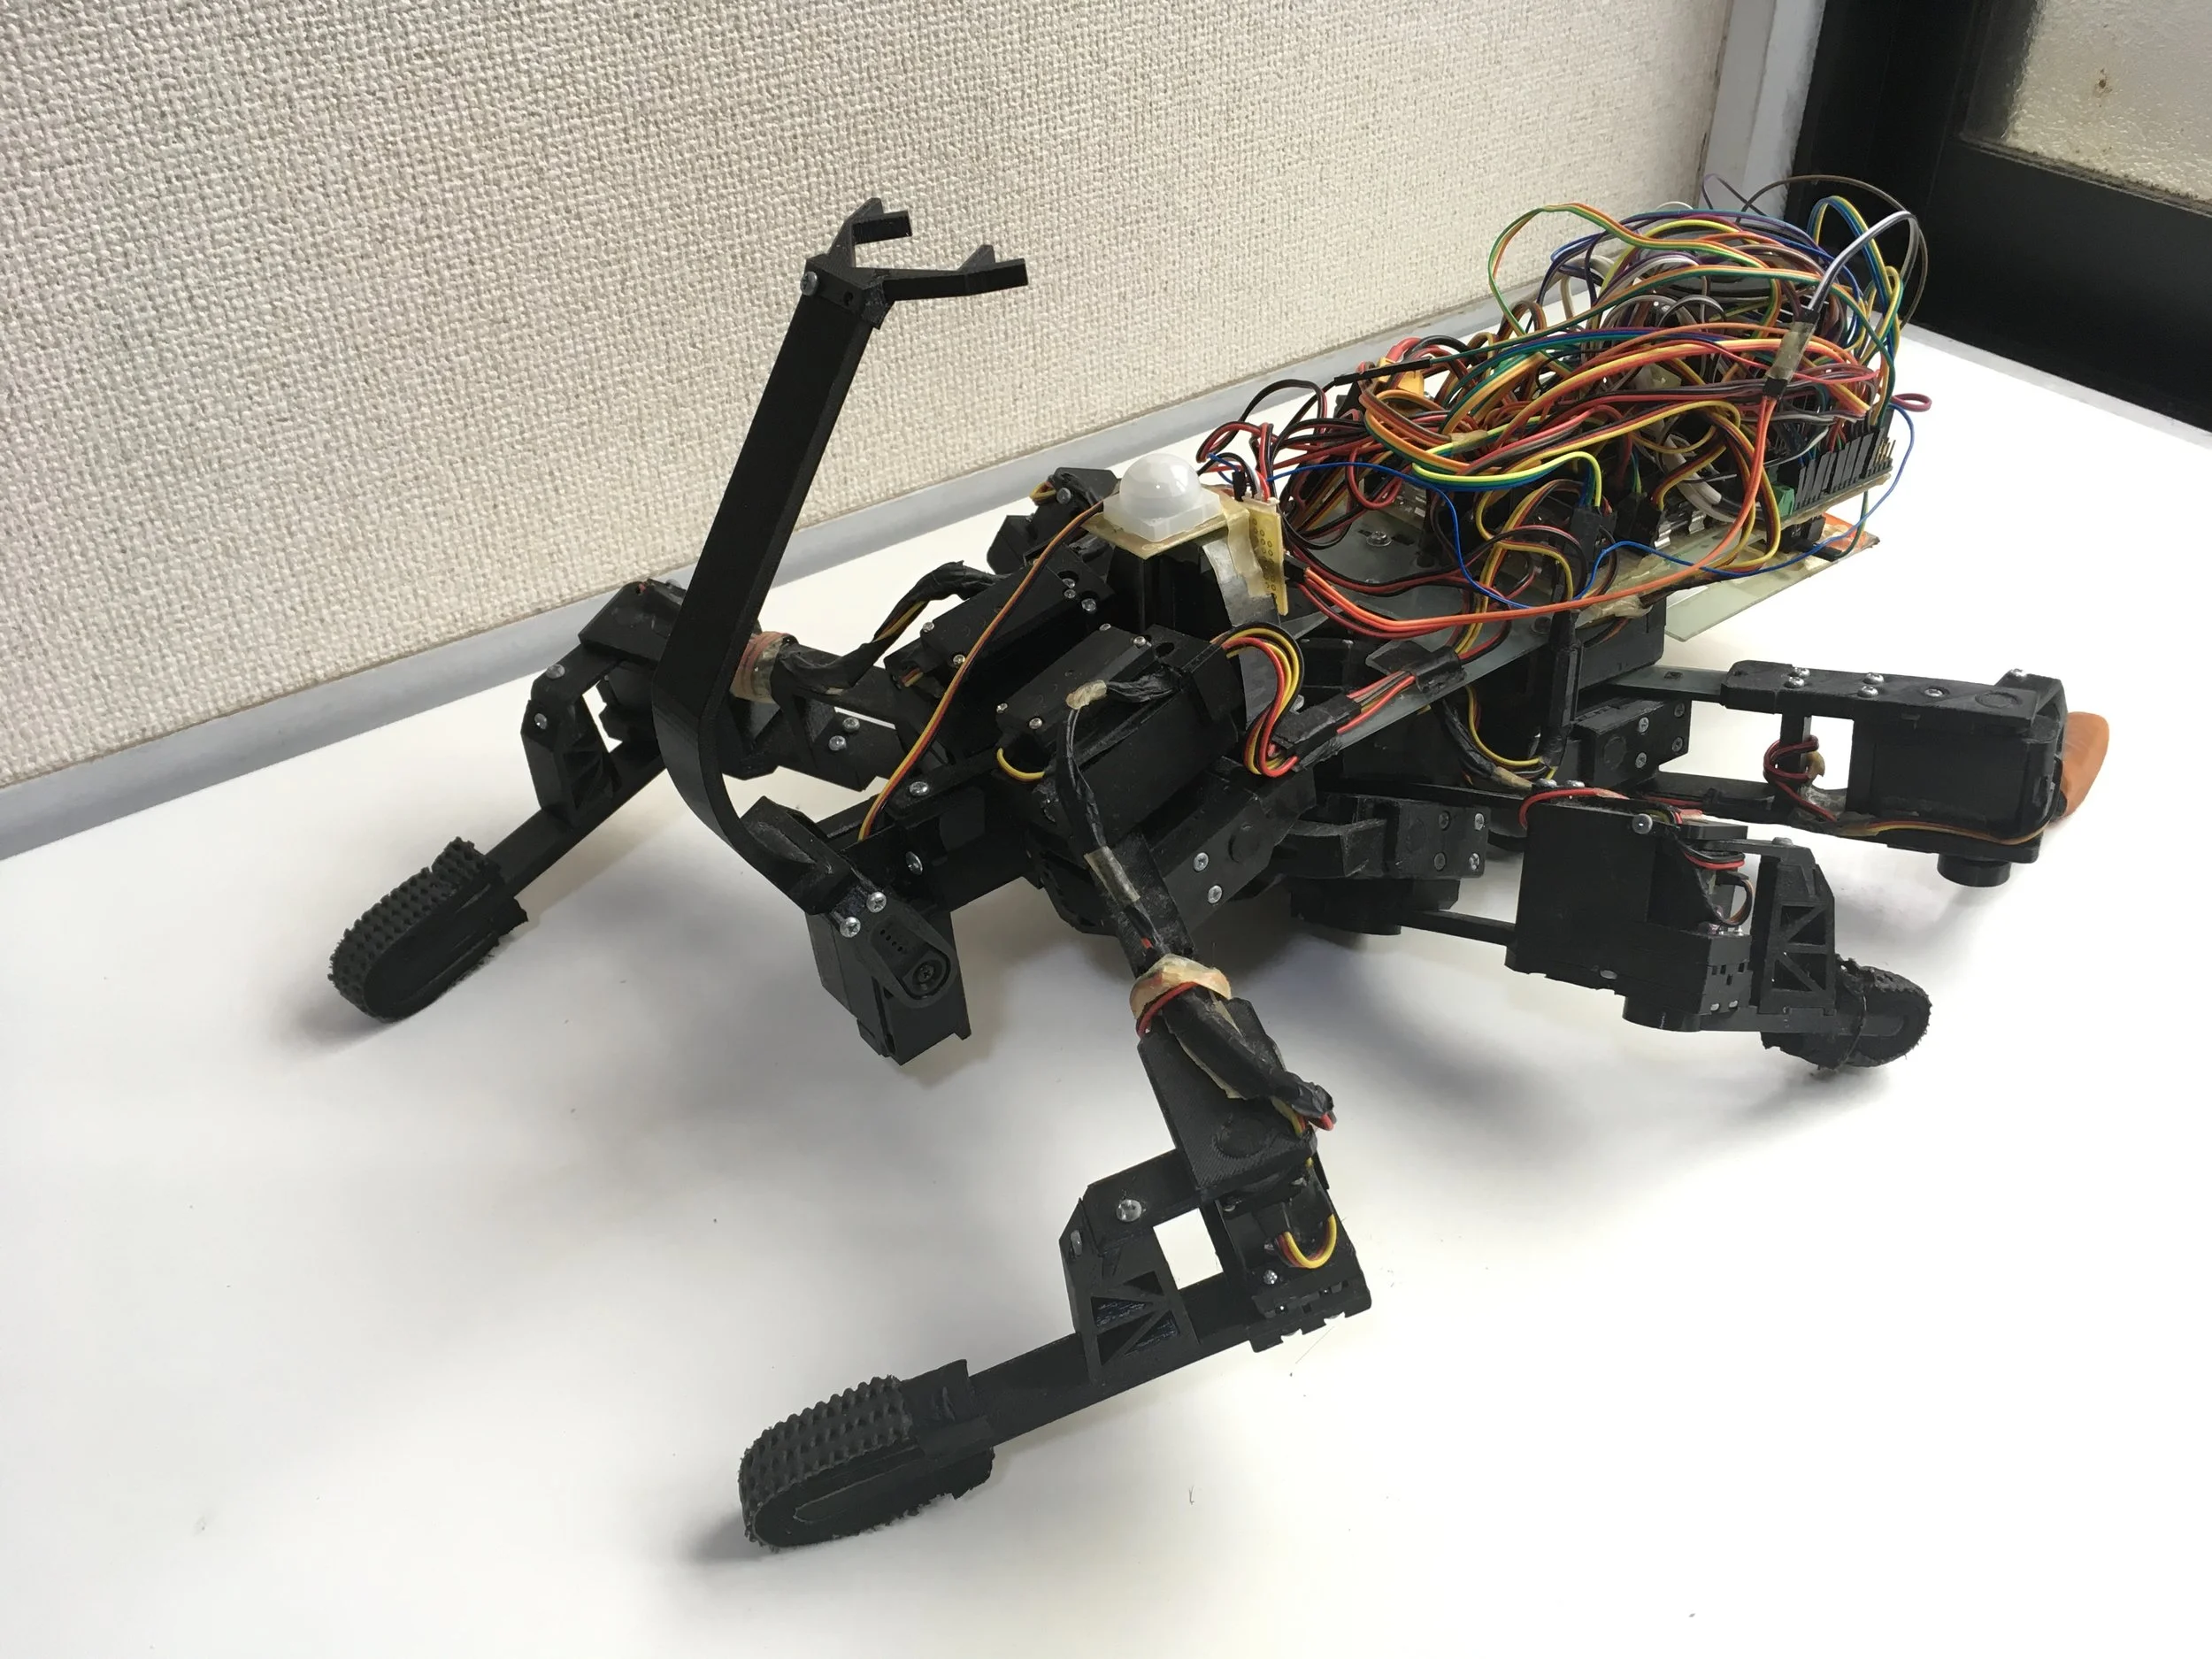
High school project where I built a Rhinoceros beetle robot. Fully 3D printed with custom PCB. Unlike most hexapods, the legs follow a true anatomical beetle pattern with legs able to kick backwards.
Skills: CAD, PCB
Telexistence
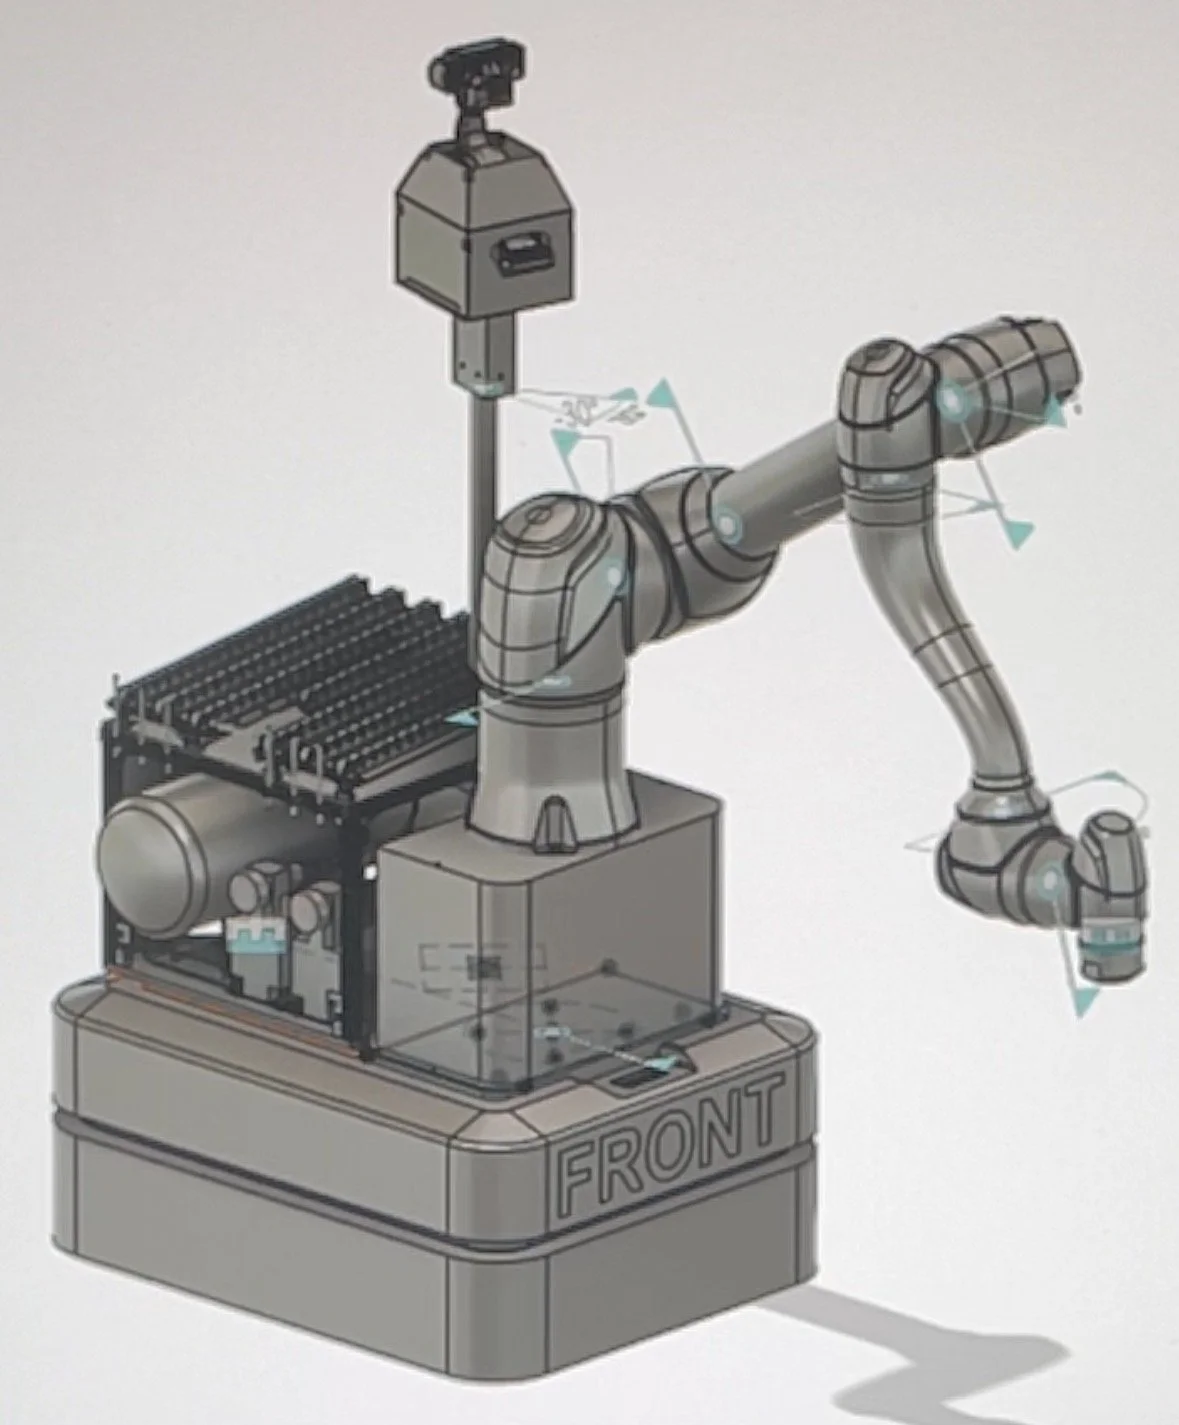
Internship working on teleoperated pallet loading robot. I was responsible for redesigning camera mounts so that the FOV was optimal for Human/AI control.
Skills: CAD, integration, testing
Connected Robotics
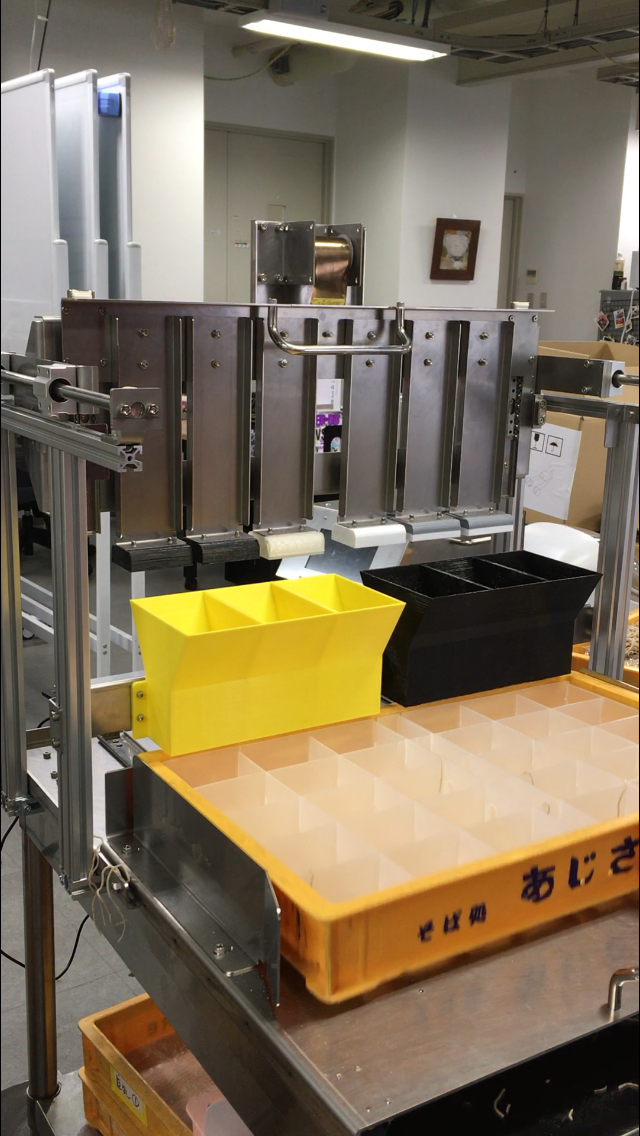
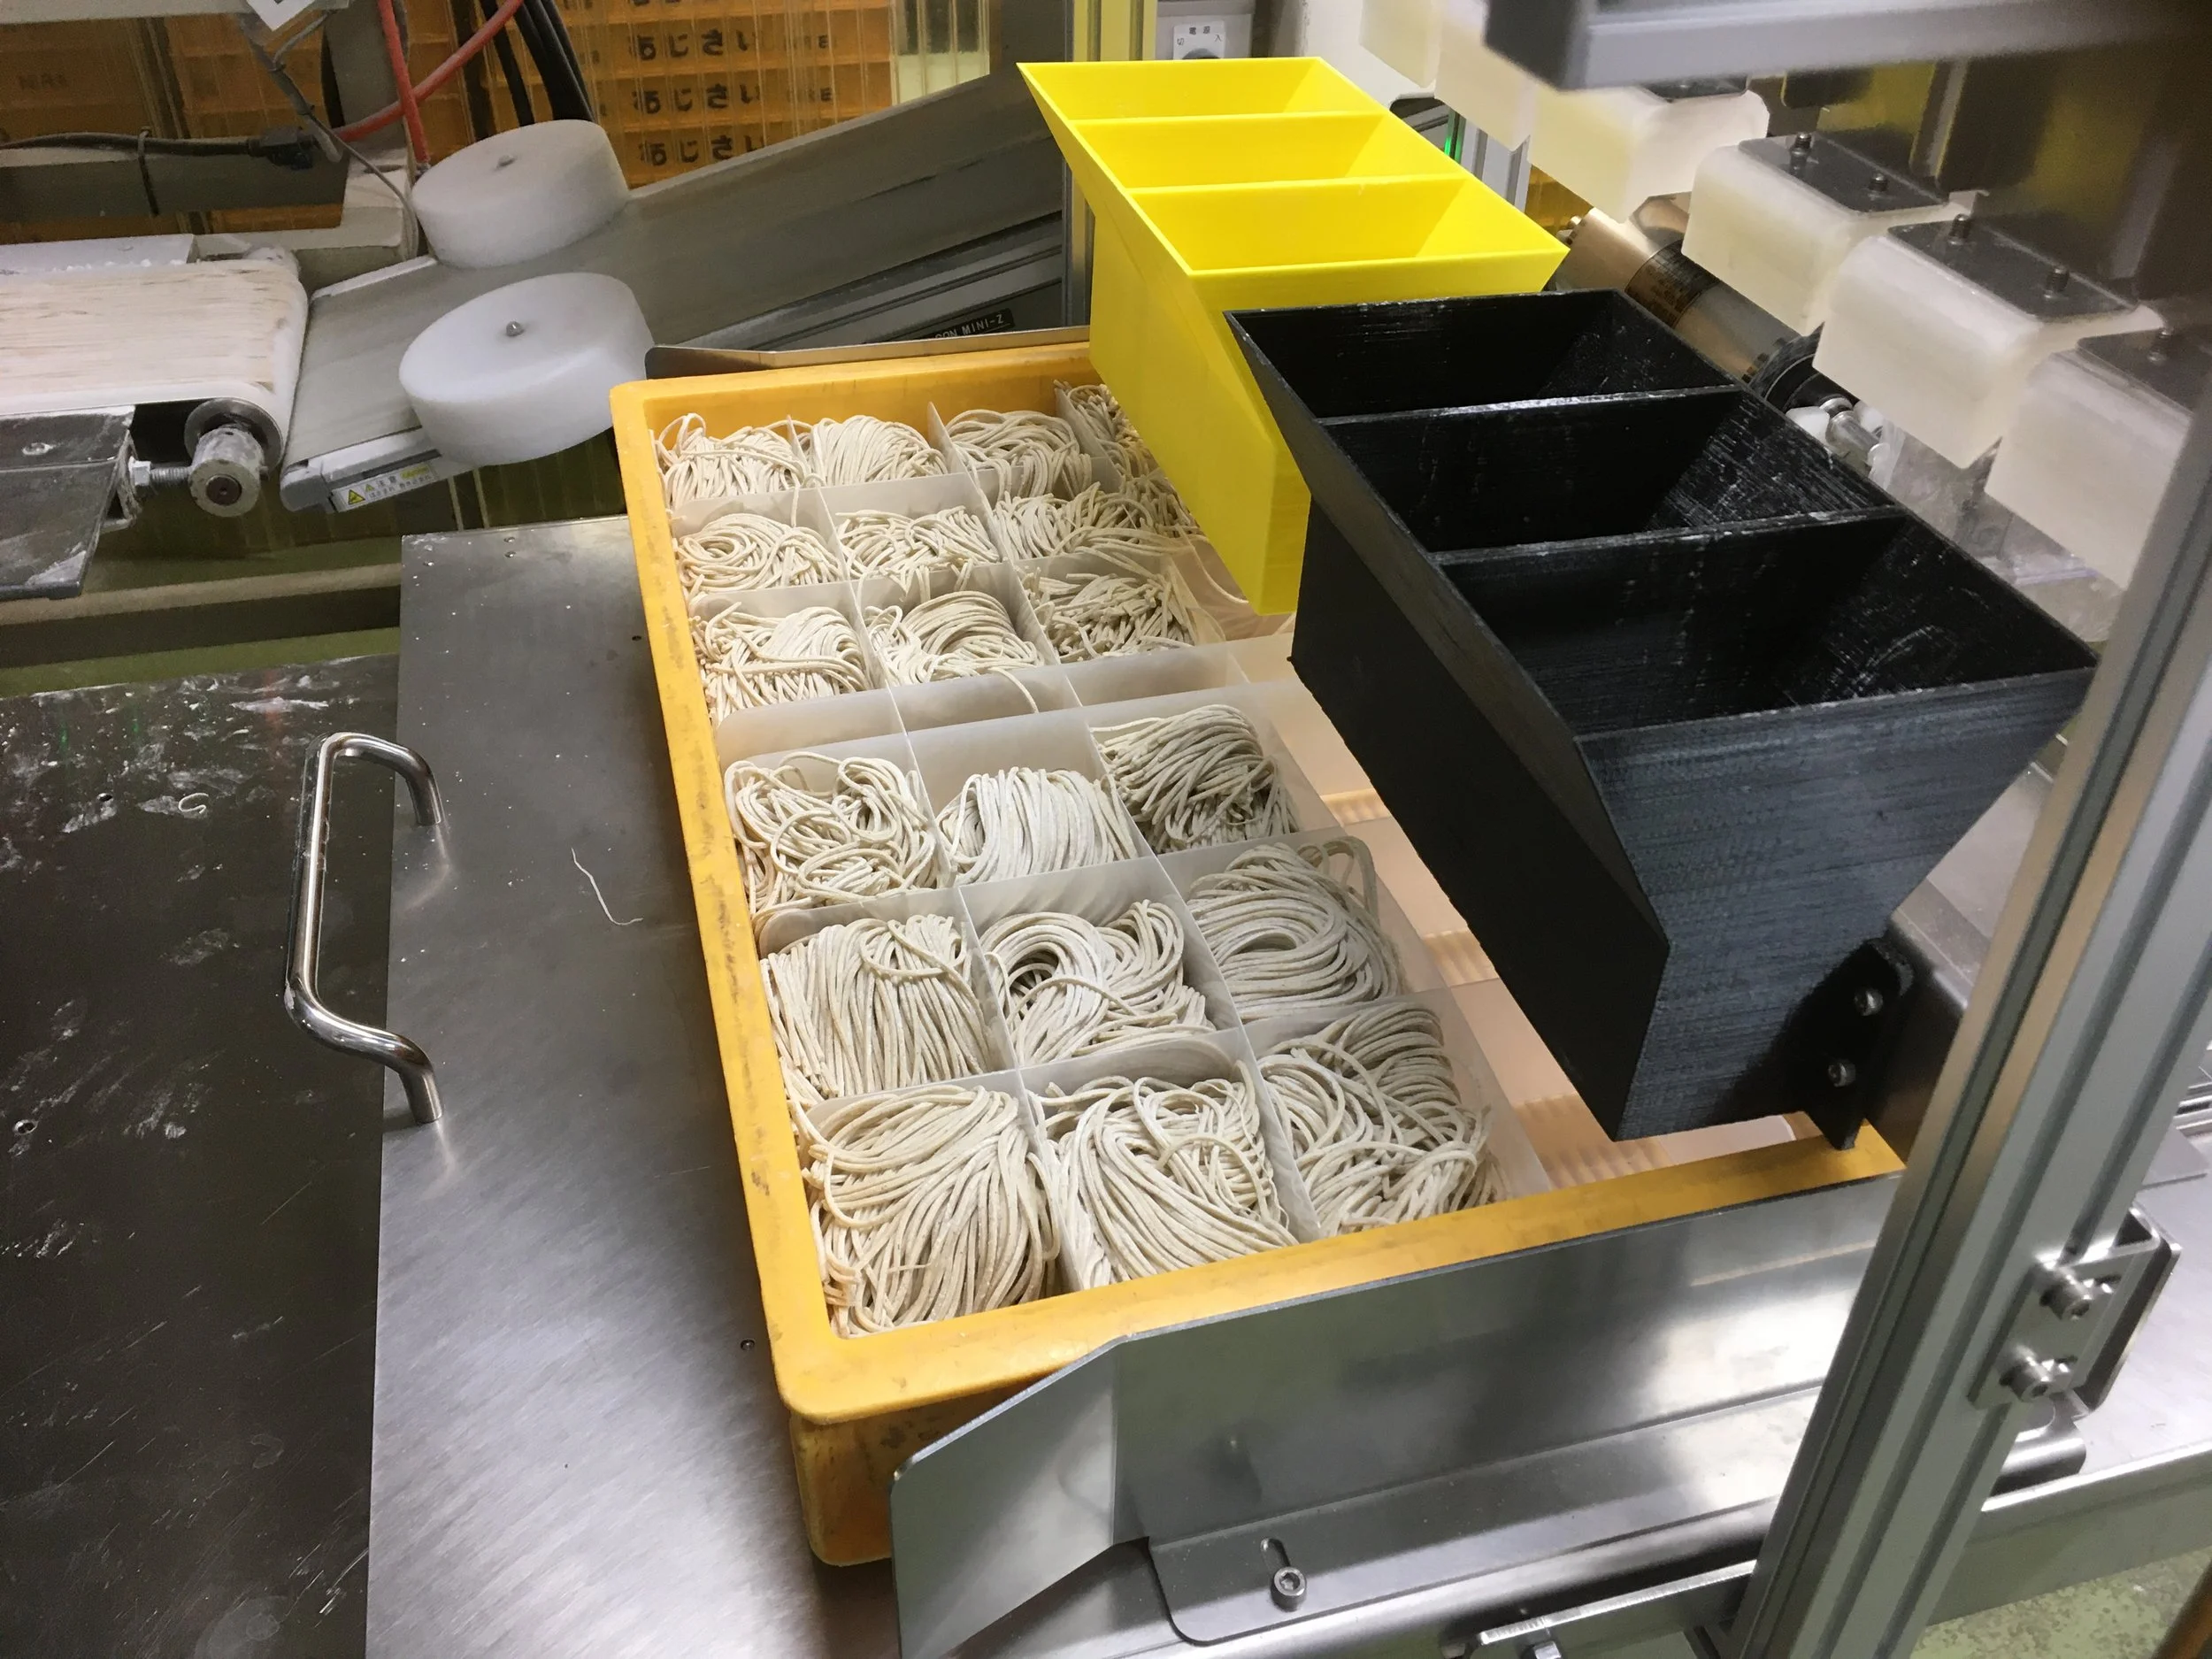
Cooking Robot startup where I designed and built a mechanism to rapidly pack soba noodles into a tray, and conducted factory testing and instructed workers about operation. Prototyped a burger flipping end effector for cobot use.
Skills: Sheet Metal design, Communication with factory workers.